Building the Data Layer for Physical AI
Since 2017, Imagine.io has powered 3D product content and configurator technology for manufacturers and retailers. That same infrastructure and expertise now builds the environments physical AI trains on.
From Product Visualization to Physical AI
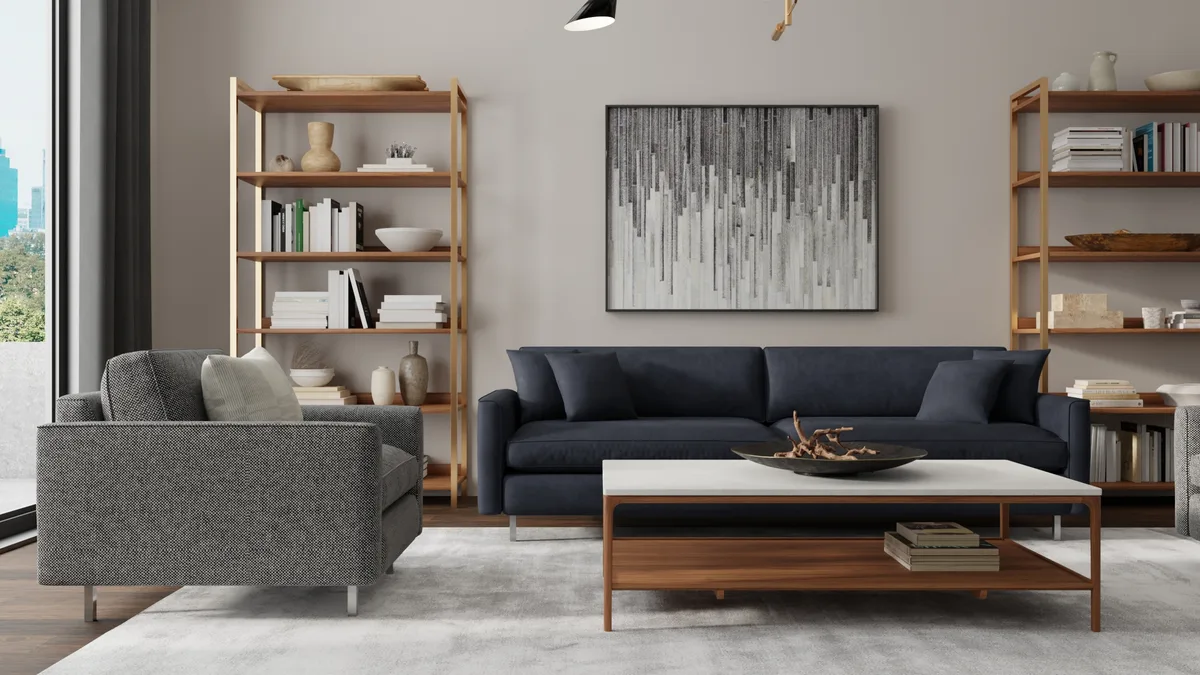
Imagine.io started by powering 3D product content and configurator experiences for manufacturers and retailers. The team built workflows for authoring product geometry, materials and reusable scene content at production scale.
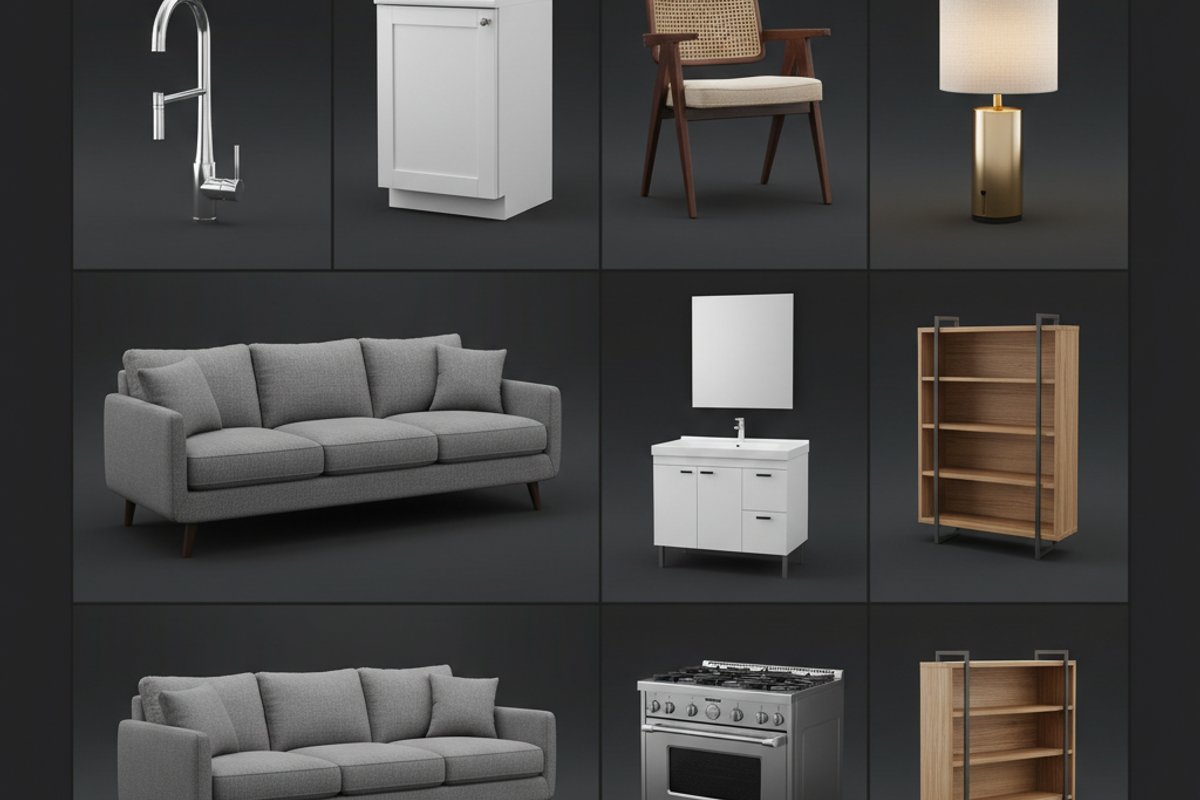
simgenerator brings that experience to robotics simulation through hand-authored libraries, AI asset and environment generation, and custom digital twins. Teams can inspect the content and choose the authoring approach that fits their task.
Built by People Who Know 3D Infrastructure
Imagine.io was founded in 2017 in San Francisco with a single focus: making real-world products available as high-fidelity digital assets at scale.
The team brings together expertise in 3D geometry processing, computer vision, real-time rendering, and production pipeline engineering. That experience supports geometry, material and scene authoring for teams building simulation workflows.
The next step is task-specific: define the objects, interactions and environment your robot needs, then inspect the authored properties and test the content in your target simulator.
- Founded
- 2017
- Headquarters
- San Francisco, CA
- Focus
- Physical AI data infrastructure
- Team
- 3D engineering, computer vision, pipeline automation
- Authoring approaches
- Hand-authored and AI-generated
- Years in production
- 8+
Built Around OpenUSD and SimReady Foundation
Imagine.io is a member of the NVIDIA Inception program. simgenerator uses OpenUSD and follows NVIDIA SimReady Foundation as an authoring standard. Inspect each package’s physics schemas and validation findings, then confirm its compatibility with your simulator version.
What We Believe
The principles that guide how we build.
Choose the right starting point
Start with a hand-authored library item, generate what is missing, or commission a custom asset. Evaluate the delivered properties and validation evidence for your task.
Details affect behavior
Scale, collision geometry, mass and joint settings affect simulated interaction. Define the checks your task needs and verify them in your runtime.
Scale needs automation
Reusable assets and automation help teams explore more scene variations. Keep the authored content and task checks traceable as your experiments grow.
This layer must exist
Robotics teams need environments they can inspect, adapt and test. We bring content libraries, generation and authoring tools together for that work.
Work With Us
or email us at support@imagine.io